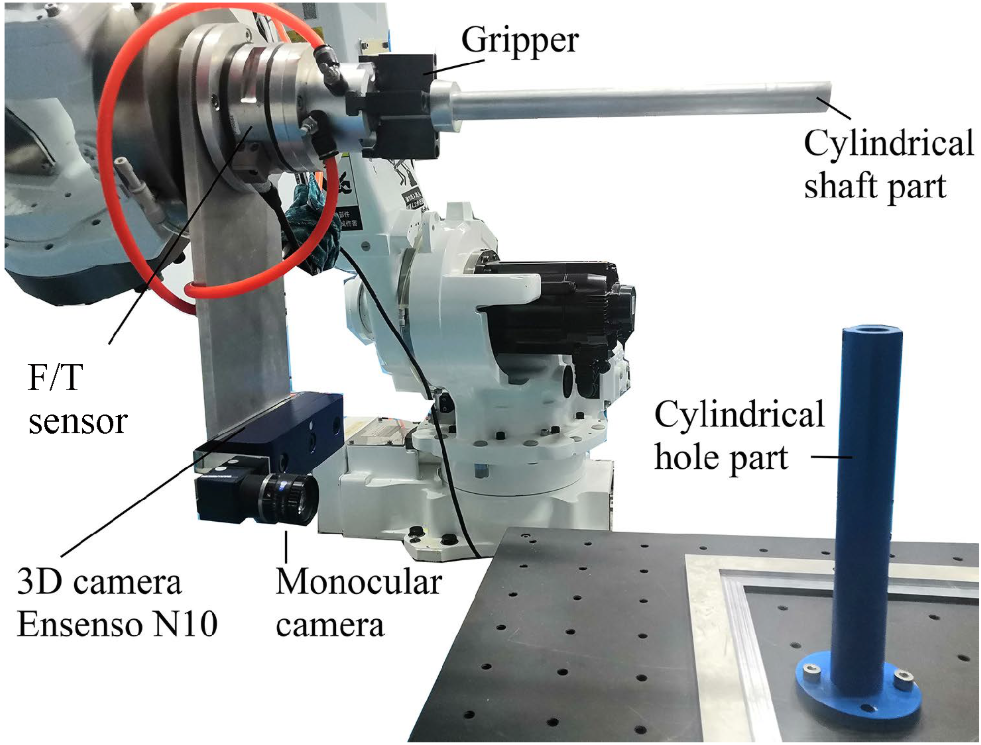
Vision- and Force-guided Robotic Manipulation for Intelligent Assembly
2019.10 -- 2022.04
Master's Student
Chongqing University, Chongqing, China
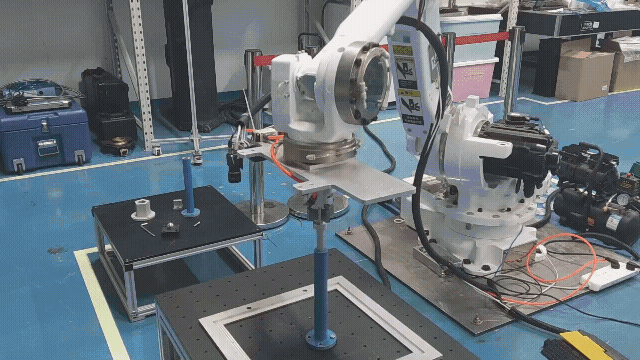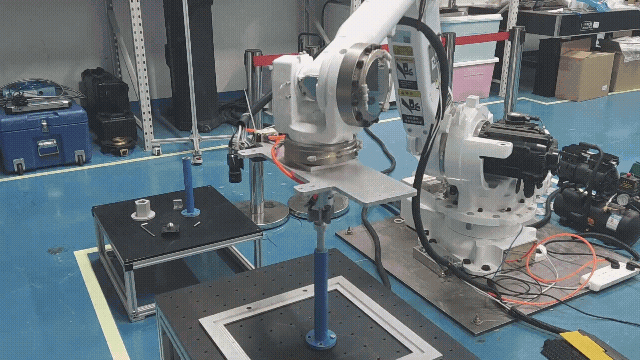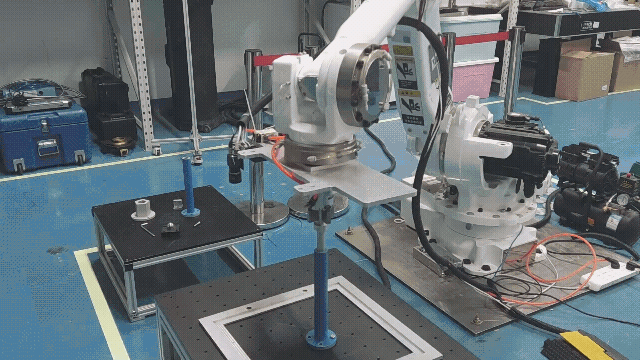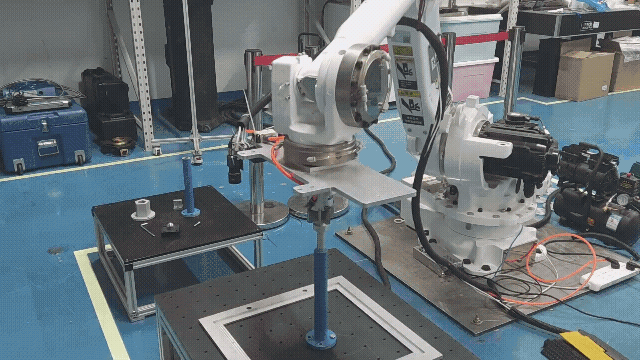
- Research deep learning for image-based object detection and point-cloud-based 6-DoF pose estimation, alongside compliant force control for robotic interaction.
- Develop a robotic hand–eye system integrating a manipulator, 3D camera, and six-axis force sensor for autonomous assembly.