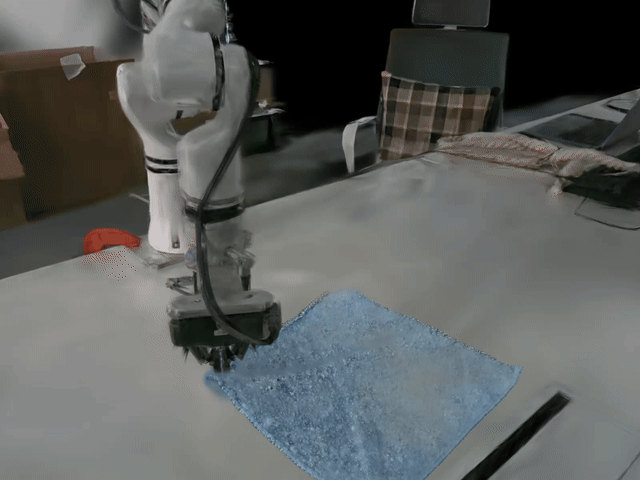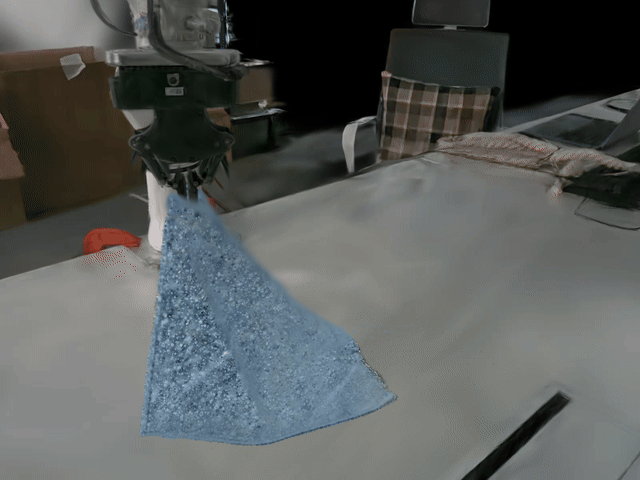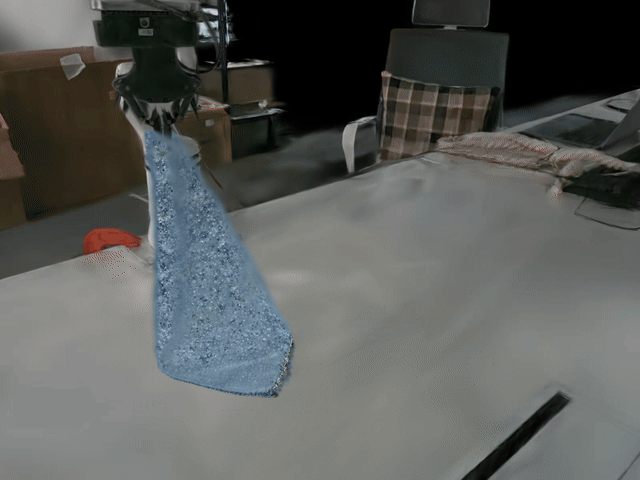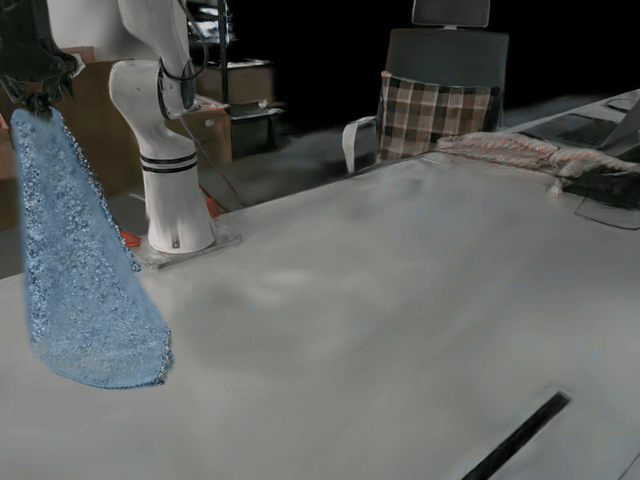
Interactive Physics-driven 4D World Models (DeformMaster, DeformSmith)
2025.09 -- 2026.09
Research Intern
A4x, Hangzhou, China
- 3D reconstruction and dynamics: Recover deformable objects' geometry, appearance, and motion from videos, combining differentiable rendering (Gaussian Splatting), differentiable physics (MPM, spring–mass), and neural dynamics to model deformation, physical properties, and motion.
- Interactive simulation and novel-view rendering: Simulate motion and deformation under new actions with reconstructed physics-driven 4D world models, supporting real-time online rollouts, novel-view rendering, and material parameter adjustment for deformable-object manipulation. See DeformMaster.
- Physics-driven 3D asset generation: Build a Physics Harness-guided Planner–Designer–Critic agent framework to generate interactive, reusable 3D assets from text or a single image, progressively constructing and validating geometry, physical models, material behavior, and robot interactions. See DeformSmith.